#include <praStar2.h>
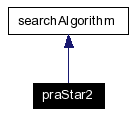
Inheritance diagram for praStar2:
Public Member Functions | |
| praStar2 () | |
| virtual | ~praStar2 () |
| virtual path * | getPath (graphAbstraction *aMap, node *from, node *to, reservationProvider *rp=0) |
| virtual const char * | getName () |
| void | setPartialPathLimit (int limit) |
| int | getPartialPathLimit () |
| void | setEnhancedAbstractPathing (bool enhance) |
| void | setExpandSearchRadius (bool _expandSearchRadius) |
| Set whether we want to expand the corridor to search in. | |
| void | setPlanFromMiddle (bool _planFromMiddle) |
| Set whether we want to start planning in the middle between base and top level of abstraction. | |
| void | setFixedPlanLevel (int p) |
| Set the level of abstraction to start pathfinding at. | |
| void | setSkipParameter (int _skip) |
| Set how many abstraction layers should be skipped at each step. | |
| int | getTopLevel () |
| int | getNumLevelsUsed () |
Protected Member Functions | |
| void | setupSearch (graphAbstraction *aMap, std::vector< node * > &fromChain, node *from, std::vector< node * > &toChain, node *to) |
| path * | buildNextAbstractPath (graphAbstraction *, path *lastPath, std::vector< node * > &fromChain, std::vector< node * > &toChain, reservationProvider *) |
| path * | trimPath (path *lastPath, node *origDest) |
| void | selectTopAbstractionLevel (graphAbstraction *aMap, std::vector< node * > &fromChain, std::vector< node * > &toChain) |
Protected Attributes | |
| int | partialLimit |
| bool | enhancedAbstractPathing |
| bool | expandSearchRadius |
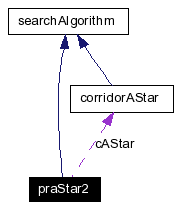
| corridorAStar | cAStar |
| char | algName [30] |
| bool | planFromMiddle |
| int | fixedPlanLevel |
| int | skip |
| int | topLevel |
| int | numLevels |
|
|
|
|
|
|
|
||||||||||||||||||||||||
|
|
|
|
Implements searchAlgorithm. |
|
|
|
|
|
|
|
||||||||||||||||||||
|
Implements searchAlgorithm. |
|
|
|
|
||||||||||||||||
|
|
|
|
|
|
|
Set whether we want to expand the corridor to search in. Set whether we want to expand the corridor from just the parents along the path to these parents and their neighbors |
|
|
Set the level of abstraction to start pathfinding at. Setting the fixed plan level to -1 will do dynamic level selection if setPlanFromMiddle is true, and it will start at the highest possible level if setPlanFromMiddle is false. Default is -1. |
|
|
|
|
|
Set whether we want to start planning in the middle between base and top level of abstraction. If true, sets the top level for pathfinding to be the level in the middle between the top level and the base level of abstraction. If false, top level for pathfinding is the topmost abstraction if fixedPlanLevel=-1, and the fixedPlanLevel otherwise. |
|
|
Set how many abstraction layers should be skipped at each step. A skip of -1 will only do pathfinding at the top level of abstraction and at the base level. A skip of 0 is the default, which will do pathfinding at each level. |
|
||||||||||||||||||||||||
|
|
|
||||||||||||
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
 1.3.4