Main Page | Namespace List | Class Hierarchy | Class List | File List | Namespace Members | Class Members | File Members | Related Pages

Koenigs Class Reference

#include <Koenigs.h>

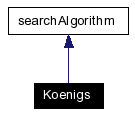
Inheritance diagram for Koenigs:

Inheritance graph
[legend]
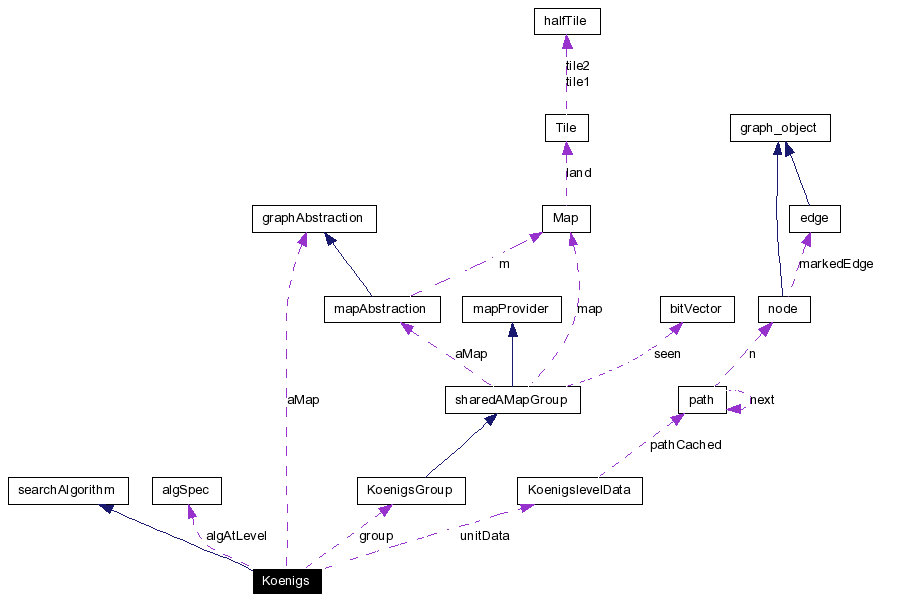
Collaboration diagram for Koenigs:

Collaboration graph
[legend]
List of all members.

Public Member Functions

 Koenigs ()
 Koenigs (int sizeLSS)
virtual ~Koenigs ()
void setParams (KoenigslevelData *_unitData, KoenigsGroup *_group)
 Get the parameters of the Koenigs unit and set them inside Koenigs.

path * getPath (graphAbstraction *aMap, node *from, node *to, reservationProvider *rp=NULL)
 The wrapper for the main procedure.

virtual const char * getName ()
int getNumAbsLevels ()
void resetNewlySeenCount ()
int getNewlySeenCount ()
graphAbstraction * getAMap ()

Private Member Functions

void setCorridorIndex (node *n, int index)
 Sets the corridor index of a node.

void setClosedListIndex (node *n, int index)
 Sets the closed list index of a node.

void setDepth (node *n, int depth)
 Sets the depth of a node.

void setgValue (node *n, double g)
 Sets the g-value of a node.

int getCorridorIndex (node *n)
 Gets the corridor index of a node.

int getClosedListIndex (node *n)
 Gets the closed list index of a node.

int getDepth (node *n)
 Gets the depth of a node.

double getgValue (node *n)
 Gets the g-value of a node.

int getAllocateENI (node *n)
 Given a node, return the index of the corresponding extended node.

int getENI (node *n)
 Tells us if the node is in the extNodes array.

void generateName (char *name)
 Generates algorithm's name.

void resetCachedPaths ()
 Clears the cached paths and corridors.

int defineCorridor (int aLevel)
 Finds and marks the corridor that restricts search at the given level.

void markCorridor (corridor *c)
 Mark the corridor in extNodes for a constant time lookup.

void relaxEdge (heap *nodeHeap, graph *g, edge *e, int source, int nextNode, node *d, graphAbstraction *map)
 This is the standard definition of relaxation as in Introduction to Algorithms (cormen, leiserson and rivest).

void aStarLSS (graphAbstraction *map, node *from, node *to, reservationProvider *rp)
 Define the local search space (LSS) in terms of the first n states expanded by an A* search.

void relaxLSS (graphAbstraction *map, node *from, node *to)
 Update the heuristic values in the local search space (LSS) using Dijkstra's algorithm, as prescribed by Koenig in "A Comparison of Fast Search Methods for Real-Time Situated Agents".

path * greedyPathLSS (graphAbstraction *aMap, node *from, node *to, reservationProvider *rp)
 Returns a path generated by using the greedy strategy: repeatedly move from the current state to the neighboring state s that minimizes f; ties are broken in favor of staying in the LSS.


Private Attributes

char KoenigsName [128]
graphAbstraction * aMap
KoenigsGroup * group
int numAbsLevels
algSpec * algAtLevel
KoenigslevelData * unitData
std::deque< extNode > extNodes
int newlySeenCount
std::vector< node * > _LSS
std::map< node *, bool, ltNodePtr > _inLSS
unsigned int _sizeLSS

Friends

class KoenigsGroup

Constructor & Destructor Documentation

Koenigs::Koenigs (   ) 
 

Koenigs::Koenigs (  int  sizeLSS  ) 
 

Koenigs::~Koenigs (   )  [virtual]


Member Function Documentation

void Koenigs::aStarLSS (  graphAbstraction *  map,
node *  from,
node *  to,
reservationProvider *  rp
)  [inline, private]
 

Define the local search space (LSS) in terms of the first n states expanded by an A* search.

This code taken from Nathan's A* implementation in aStar.cpp

int Koenigs::defineCorridor (  int  aLevel  )  [private]
 

Finds and marks the corridor that restricts search at the given level.

Returns -1 if no corridor is defined above us

void Koenigs::generateName (  char *  name  )  [private]
 

Generates algorithm's name.

int Koenigs::getAllocateENI (  node *  n  )  [inline, private]
 

Given a node, return the index of the corresponding extended node.

Create one if needed

graphAbstraction* Koenigs::getAMap (   )  [inline]
 

int Koenigs::getClosedListIndex (  node *  n  )  [inline, private]
 

Gets the closed list index of a node.

int Koenigs::getCorridorIndex (  node *  n  )  [inline, private]
 

Gets the corridor index of a node.

int Koenigs::getDepth (  node *  n  )  [inline, private]
 

Gets the depth of a node.

int Koenigs::getENI (  node *  n  )  [inline, private]
 

Tells us if the node is in the extNodes array.

double Koenigs::getgValue (  node *  n  )  [inline, private]
 

Gets the g-value of a node.

virtual const char* Koenigs::getName (   )  [inline, virtual]
 

Implements searchAlgorithm.

int Koenigs::getNewlySeenCount (   )  [inline]
 

int Koenigs::getNumAbsLevels (   )  [inline]
 

path * Koenigs::getPath (  graphAbstraction *  aMap,
node *  from,
node *  to,
reservationProvider *  rp = NULL
)  [virtual]
 

The wrapper for the main procedure.

Implements searchAlgorithm.

path * Koenigs::greedyPathLSS (  graphAbstraction *  aMap,
node *  from,
node *  to,
reservationProvider *  rp
)  [private]
 

Returns a path generated by using the greedy strategy: repeatedly move from the current state to the neighboring state s that minimizes f; ties are broken in favor of staying in the LSS.

void Koenigs::markCorridor (  corridor *  c  )  [private]
 

Mark the corridor in extNodes for a constant time lookup.

void Koenigs::relaxEdge (  heap *  nodeHeap,
graph *  g,
edge *  e,
int  source,
int  nextNode,
node *  d,
graphAbstraction *  map
)  [inline, private]
 

This is the standard definition of relaxation as in Introduction to Algorithms (cormen, leiserson and rivest).

This code taken from Nathan's A* implementation in aStar.cpp

void Koenigs::relaxLSS (  graphAbstraction *  map,
node *  from,
node *  to
)  [inline, private]
 

Update the heuristic values in the local search space (LSS) using Dijkstra's algorithm, as prescribed by Koenig in "A Comparison of Fast Search Methods for Real-Time Situated Agents".

(1) Go through the LSS and, for each state s on the border of the LSS, enter s into a heap with the appropriate cost.

(2) Remove the 'best' state from the top of the heap and set its h value. Relax the neighbors (update their potential h values) and repeat.

void Koenigs::resetCachedPaths (   )  [private]
 

Clears the cached paths and corridors.

void Koenigs::resetNewlySeenCount (   )  [inline]
 

void Koenigs::setClosedListIndex (  node *  n,
int  index
)  [inline, private]
 

Sets the closed list index of a node.

void Koenigs::setCorridorIndex (  node *  n,
int  index
)  [inline, private]
 

Sets the corridor index of a node.

void Koenigs::setDepth (  node *  n,
int  depth
)  [inline, private]
 

Sets the depth of a node.

void Koenigs::setgValue (  node *  n,
double  g
)  [inline, private]
 

Sets the g-value of a node.

void Koenigs::setParams (  KoenigslevelData *  _unitData,
KoenigsGroup *  _group
) 
 

Get the parameters of the Koenigs unit and set them inside Koenigs.


Friends And Related Function Documentation

friend class KoenigsGroup [friend]


Member Data Documentation

std::map<node*, bool, ltNodePtr> Koenigs::_inLSS [private]
 

std::vector<node*> Koenigs::_LSS [private]
 

unsigned int Koenigs::_sizeLSS [private]
 

algSpec* Koenigs::algAtLevel [private]
 

graphAbstraction* Koenigs::aMap [private]
 

std::deque<extNode> Koenigs::extNodes [private]
 

KoenigsGroup* Koenigs::group [private]
 

char Koenigs::KoenigsName[128] [private]
 

int Koenigs::newlySeenCount [private]
 

int Koenigs::numAbsLevels [private]
 

KoenigslevelData* Koenigs::unitData [private]


The documentation for this class was generated from the following files:
Generated on Tue Aug 18 03:43:06 2009 for HOG by doxygen 1.3.4